Research
MORIN Lab studies autonomy and intelligence for mobile robotic systems, with a strong emphasis on marine applications. Our research is organized around four closely related themes spanning dynamics and control, autonomous ship operations, navigation and mapping, and cooperative robotic systems.
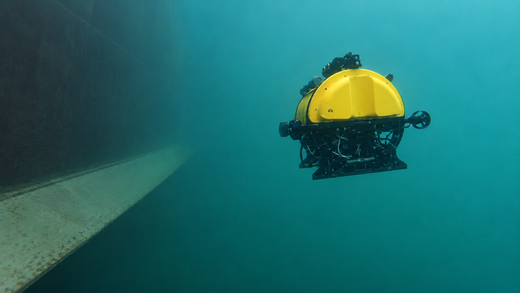
Autonomous Marine & Field Robotics
- Dynamics, guidance and control of USVs/UUVs
- Theoretical and learning-based modeling and control
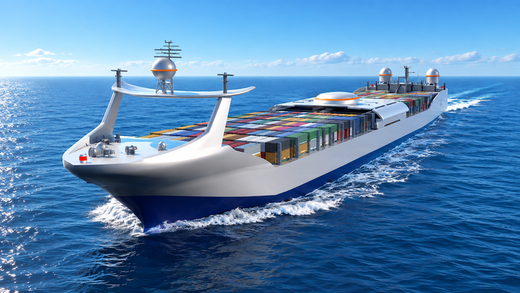
Maritime Autonomous Surface Ships (MASS)
- Maritime situational awareness and automated ship operations
- COLREGs-compliant collision avoidance, reachability-based safety analysis
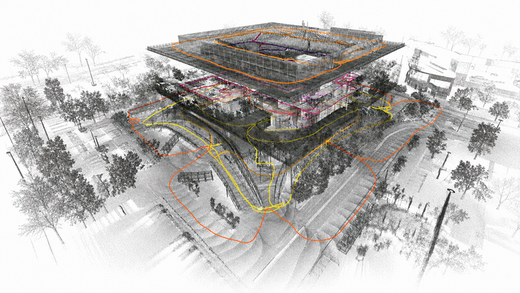
Navigation, Mapping & SLAM in Challenging Environments
- Navigation and mapping in GPS-denied environments
- Geophysical navigation & SLAM in underwater environment
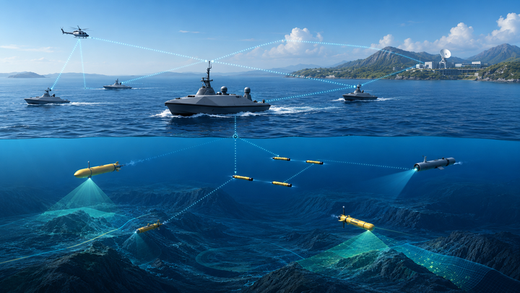
Multi-Robot Coordination & Mission Planning
- Multi-vehicle planning, task allocation and scheduling
- Informative path planning for search and mapping missions